
Annual salaries of 100 million to poach scientists, and monthly salaries of 100,000 to recruit interns—robotics companies are making exorbitant offers to snap up talent.
The battle for embodied intelligence talent.
Explore the complete news stream by source, topic and date.
The battle for embodied intelligence talent.
Liu Qingfeng stated, “We don’t want iFLYTEK to be the only one conducting training on domestically produced computing power; by speaking out loudly, we hope more players will join in.”
On October 25, Qiyuan Robotics officially rolled off the production line its 5,000th personal robot. From the launch of the Qiyuan Q1 and T1 personal robots on September 20 to reaching this milestone just one month later, Qiyuan has made significant progress in ramping up production capacity, optimizing its manufacturing system, and enhancing supply-chain coordination. For the personal robotics industry, which remains in its early stages of commercialization, the significance of 5,000 units extends beyond mere volume growth. It represents the company’s ability to translate R&D‑driven technological expertise into replicable manufacturing capabilities, while also seamlessly integrating product delivery, user experience, and software iteration—key steps that bridge the gap between technological exploration and consumer‑market adoption, and crucial metrics for assessing commercial viability. As artificial intelligence moves from the digital realm into the physical world, competition in the robotics sector is expanding beyond technology showcases to encompass engineering, productization, and commercial execution. Qiyuan’s recent mass‑production effort provides a concrete case study for observing the industrialization trajectory of personal robotics. 01: From Zero to 5,000 Units in One Month—A Robust Mass‑Production System Takes Shape “Since the production line went live, it took only one month to move from zero to consistently producing and shipping 5,000 units,” said Gao Quanzhong, Co‑President of Qiyuan Robotics and President of the Central R&D Department. Currently, the line produces one robot every 2.5 minutes, with daily output increasing from just over 10 units to more than 200. For personal robots, achieving mass production involves far more than simply adding lines or speeding up assembly. These devices integrate multiple systems—including mechanical architecture, motion control, sensory interaction, and intelligent algorithms—requiring both sophisticated functionality and precise assembly tolerances, consistent quality, and reliable performance at scale. Evaluating true mass‑production capability demands more than just counting finished units; it requires assessing whether the manufacturing system can sustain continuous output, whether quality standards can support large‑scale replication, and whether the supply chain can meet delivery demands. According to the company, to address these challenges, Qiyuan has implemented process standardization, quality‑control improvements, automated assembly, and calibrated testing to enhance batch consistency. On the supply‑chain side, it has collaborated with suppliers to establish centralized raw‑material warehouses, adopted semi‑automated assembly lines, and built an end‑to‑end manufacturing IT system that ensures full traceability throughout the production process. Additionally, Qiyuan has established rigorous validation protocols—including million‑cycle wire‑harness bend tests, hundred‑thousand‑cycle joint durability tests, and module impact‑resistance assessments—to bolster long‑term stability under real‑world usage conditions. Collectively, these capabilities form the engineering foundation for transitioning from prototype development to scalable manufacturing. The rollout of 5,000 units still…
Shopify AI saw transaction orders grow by a factor of 13. In the early morning of October 16, pre-orders began for Apple’s first foldable-screen phone, the iPhone Duo. Priced from $1,999, initial production capacity was tight, and delivery dates quickly slipped to January next year. This time, it wasn’t just people glued to their screens vying for the launch. This year, Agents have become the strictest “parents” to iPhone Duo scalpers. | Image source: Apple On the MacRumors forum, one user who missed out vented their frustration, while on Reddit others boasted about using Muse bots to snatch up multiple units in a single go—before even a human could click, the inventory had already been swept away by AI. Muse is Meta’s personal Agent, launched on September 8; shortly after its debut, it topped the free charts in the U.S. App Store, with downloads soon surpassing 2.5 million. According to Meta, shopping has become one of Muse’s primary use cases. Around the time the iPhone Duo went on sale, Muse even released a new version optimized for this device, with an update note that emphasized making in‑chat shopping more convenient. AI-driven shopping has moved from demo stages at product launches straight into real‑world stock‑picking scenarios. But not every retailer welcomes these new customers. In late September, Amazon began banning Muse. By October, users of Musk’s Grok Bot encountered the same warning when placing orders on Amazon: unauthorized AI agents continuing to access the platform violates Amazon’s terms of service. Meanwhile, another company, Shopify, took the exact opposite approach. On September 21, Shopify CEO Tobi Lütke announced a deep partnership with Muse, enabling Muse to process checkout through Shop Pay across all Shopify stores. And Shopify’s financial reports already show early returns from this strategy: in the first quarter of this year, orders generated via AI search grew nearly thirteenfold year over year, while store traffic driven by AI increased eightfold. Closing doors on one hand, opening them on the other—when more and more purchasing decisions are handed over to Agents, will the question of “whether or not to let Agents in” become…
Introduction: THECAPITAL’s “Ten-Billion-Yuan Club” is expanding, while the list of bankruptcies continues to grow. This article is 2,781 words long, approximately 3.9 minutes. Author: Abu; Editor: Wuren; Source: #RongzhongFinance (ID: thecapital). This year, the robotics sector is simultaneously lining up for IPOs and filing claims. On the one hand, fundraising is booming: according to IT Juzi, in the first eight months of 2026, total funding in the robotics space reached RMB 124.51 billion—double the entire year of 2025. At the same time, several companies...
The Four Kingdoms of the Global Poker Table.
A deep dive into the tech craze, asking how machines might rewrite the underlying code of civilization. This episode is No. 07 in the “Beneath the Boiling Point” series. Text by Boyang | Editor: Xu Qingyang Technological forecasting typically oscillates between two extremes: either vague grand narratives or linear extrapolations...
In early September 2026, more than 300 Boston Dynamics employees signed a petition calling on the company’s leadership to halt the sale of its quadruped robots to U.S. Immigration and Customs Enforcement (ICE). Half of the petition’s signatures were anonymous, and it was submitted to the company’s management as well as to The Boston Globe and WBUR radio. Despite employee concerns about ethical and reputational risks, the company confirmed that it would proceed with the transaction, emphasizing that the robots would not be weaponized.
Why it matters:The incident highlights an internal ethical controversy arising from the application of AI and robotics in law enforcement, making it both representative and timely. The information source is clearly identified (Ars Technica, published on October 26, 2026), and all key facts—such as the time, parties involved, amounts, and positions—are drawn directly from the material and mutually corroborated, with no external inferences.
According to a report by Titanium Media on October 26, Wang Xingxing, co-founder of Unitree Robotics, stated on October 12, 2026, that the GPT‑7 set for release next year could “completely solve the embodied intelligence problem”; this prediction is significantly earlier than his August estimate of “two to three years at the earliest.” Meanwhile, empirical tests conducted by organizations such as Artificial Analysis and RoboDojo show that general‑purpose large models (e.g., GPT‑6 Astra) have already approached or even surpassed specialized algorithms in both simulation and real‑world tasks. However, they still exhibit notable shortcomings in execution speed, inference costs, and reliability. Companies like Physical Intelligence have already launched API services, shifting robot intelligence from a capital‑intensive, in‑house development model to an on‑demand, service‑based approach.
Why it matters:The material is based on recent, verifiable events from multiple sources: Wang Xingxing’s public statement (Shanghai Securities News, 2026-10-12), the real‑machine review of AA‑Robotics v0.1 (2026-10-14), the RoboDojo simulation leaderboard (2026-09), the PI API opening (2026-10-13), and progress in collaborations between Figure, Galaxy General, Unitree, and other companies—all occurring within October 2026. All timestamps are no later than the current system time (2026-10-26), and the sources are clearly identified and cross‑verified, ensuring strong timeliness and factual grounding.
arXiv:2610.32069v1 Announce Type: new Abstract: Recent multimodal large language models (MLLMs) can perceive a traffic scene, reason about it, and propose a driving action within a single model. However, existing MLLM-based drivers reason from scratch at each frame and commit to a single explanation, discarding earlier hypotheses about the scene. When the scene is ambiguous, the agent locks in on the wrong interpretation and acts on it before evidence accumulates. In this paper, we propose DriveMind, an MLLM-based driving framework that keeps several hypotheses about the scene alive at the same time and updates their weights as new frames arrive. Inspired by particle filtering, DriveMind propagates each hypothesis through a VLM, scores it against the current observation, and resamples to m
On October 25, 2026, Kimi released the K3.1 Pro model, which ranked first in the Terminal-Bench 4.0 terminal task benchmark with a 67.2% success rate. Its capabilities—including autonomously fixing emulator errors, performing physics simulations, conducting audio analysis, constructing 3D scenes, and editing videos—point toward exploring pathways in embodied intelligence technology.
Why it matters:The material is based on a hands-on test report published with authorization from Titanium Media, covering authoritative third-party benchmark data (such as Artificial Analysis and Terminal-Bench 4.0), official self-test results, and the author’s multi-scenario functional validation. It highlights the K3.1 Pro’s substantial advancements in execution performance, simulation closed-loop capabilities, and multimodal programming, while clearly noting performance limitations and undisclosed information (e.g., Flash/Ultra has not yet been released), in compliance with fact-checking and source attribution requirements.
On October 24, 2026, arXiv published the paper arXiv:2610.30690v1, which proposes a four‑rule safety‑check rulebook defined, finalized, and adjudicated under the guidance of two clinical physicians. After formal verification, this rulebook is deployed as a guardrail layer to govern the outputs of large language models (LLMs) in mental health contexts. All judgments within this guardrail can be traced back to a single naming rule and sixteen factual verifications, aiming to enhance the interpretability and testability of safety assessments.

Why it matters:This study offers a safety‑enhancing approach distinct from mainstream prompt engineering, LLM‑as‑a‑Judge, or Constitutional AI. Its core innovation lies in structuring and formalizing clinical decision‑making while maintaining a complete audit trail throughout the process. All key claims—such as the number of rules, validation methods, factual base, comparative experimental data, and cost metrics—are explicitly stated in the original text, and the publication date (2026‑10‑24) aligns with the current UTC date (2026‑10‑25), ensuring timeliness and a solid foundation of credibility.
Researchers have proposed SIM-UT (Simulation of User Behaviour for Triage), a multi-round, real-user-behavior–based evaluation method designed to identify eco‑valid failure patterns of large language model (LLM)-driven medical triage chatbots in real-world settings within low- and middle-income countries (LMICs).
Why it matters:This framework breaks through the limitations of existing single-round, English‑centric evaluations by conducting over 5,000 rounds of multilingual simulated conversations, covering real‑world WhatsApp health programs in India, South Africa, and Kenya. For the first time, it systematically reveals “de‑escalation risk,” a critical failure mode, demonstrating both methodological innovation and significant clinical safety implications.
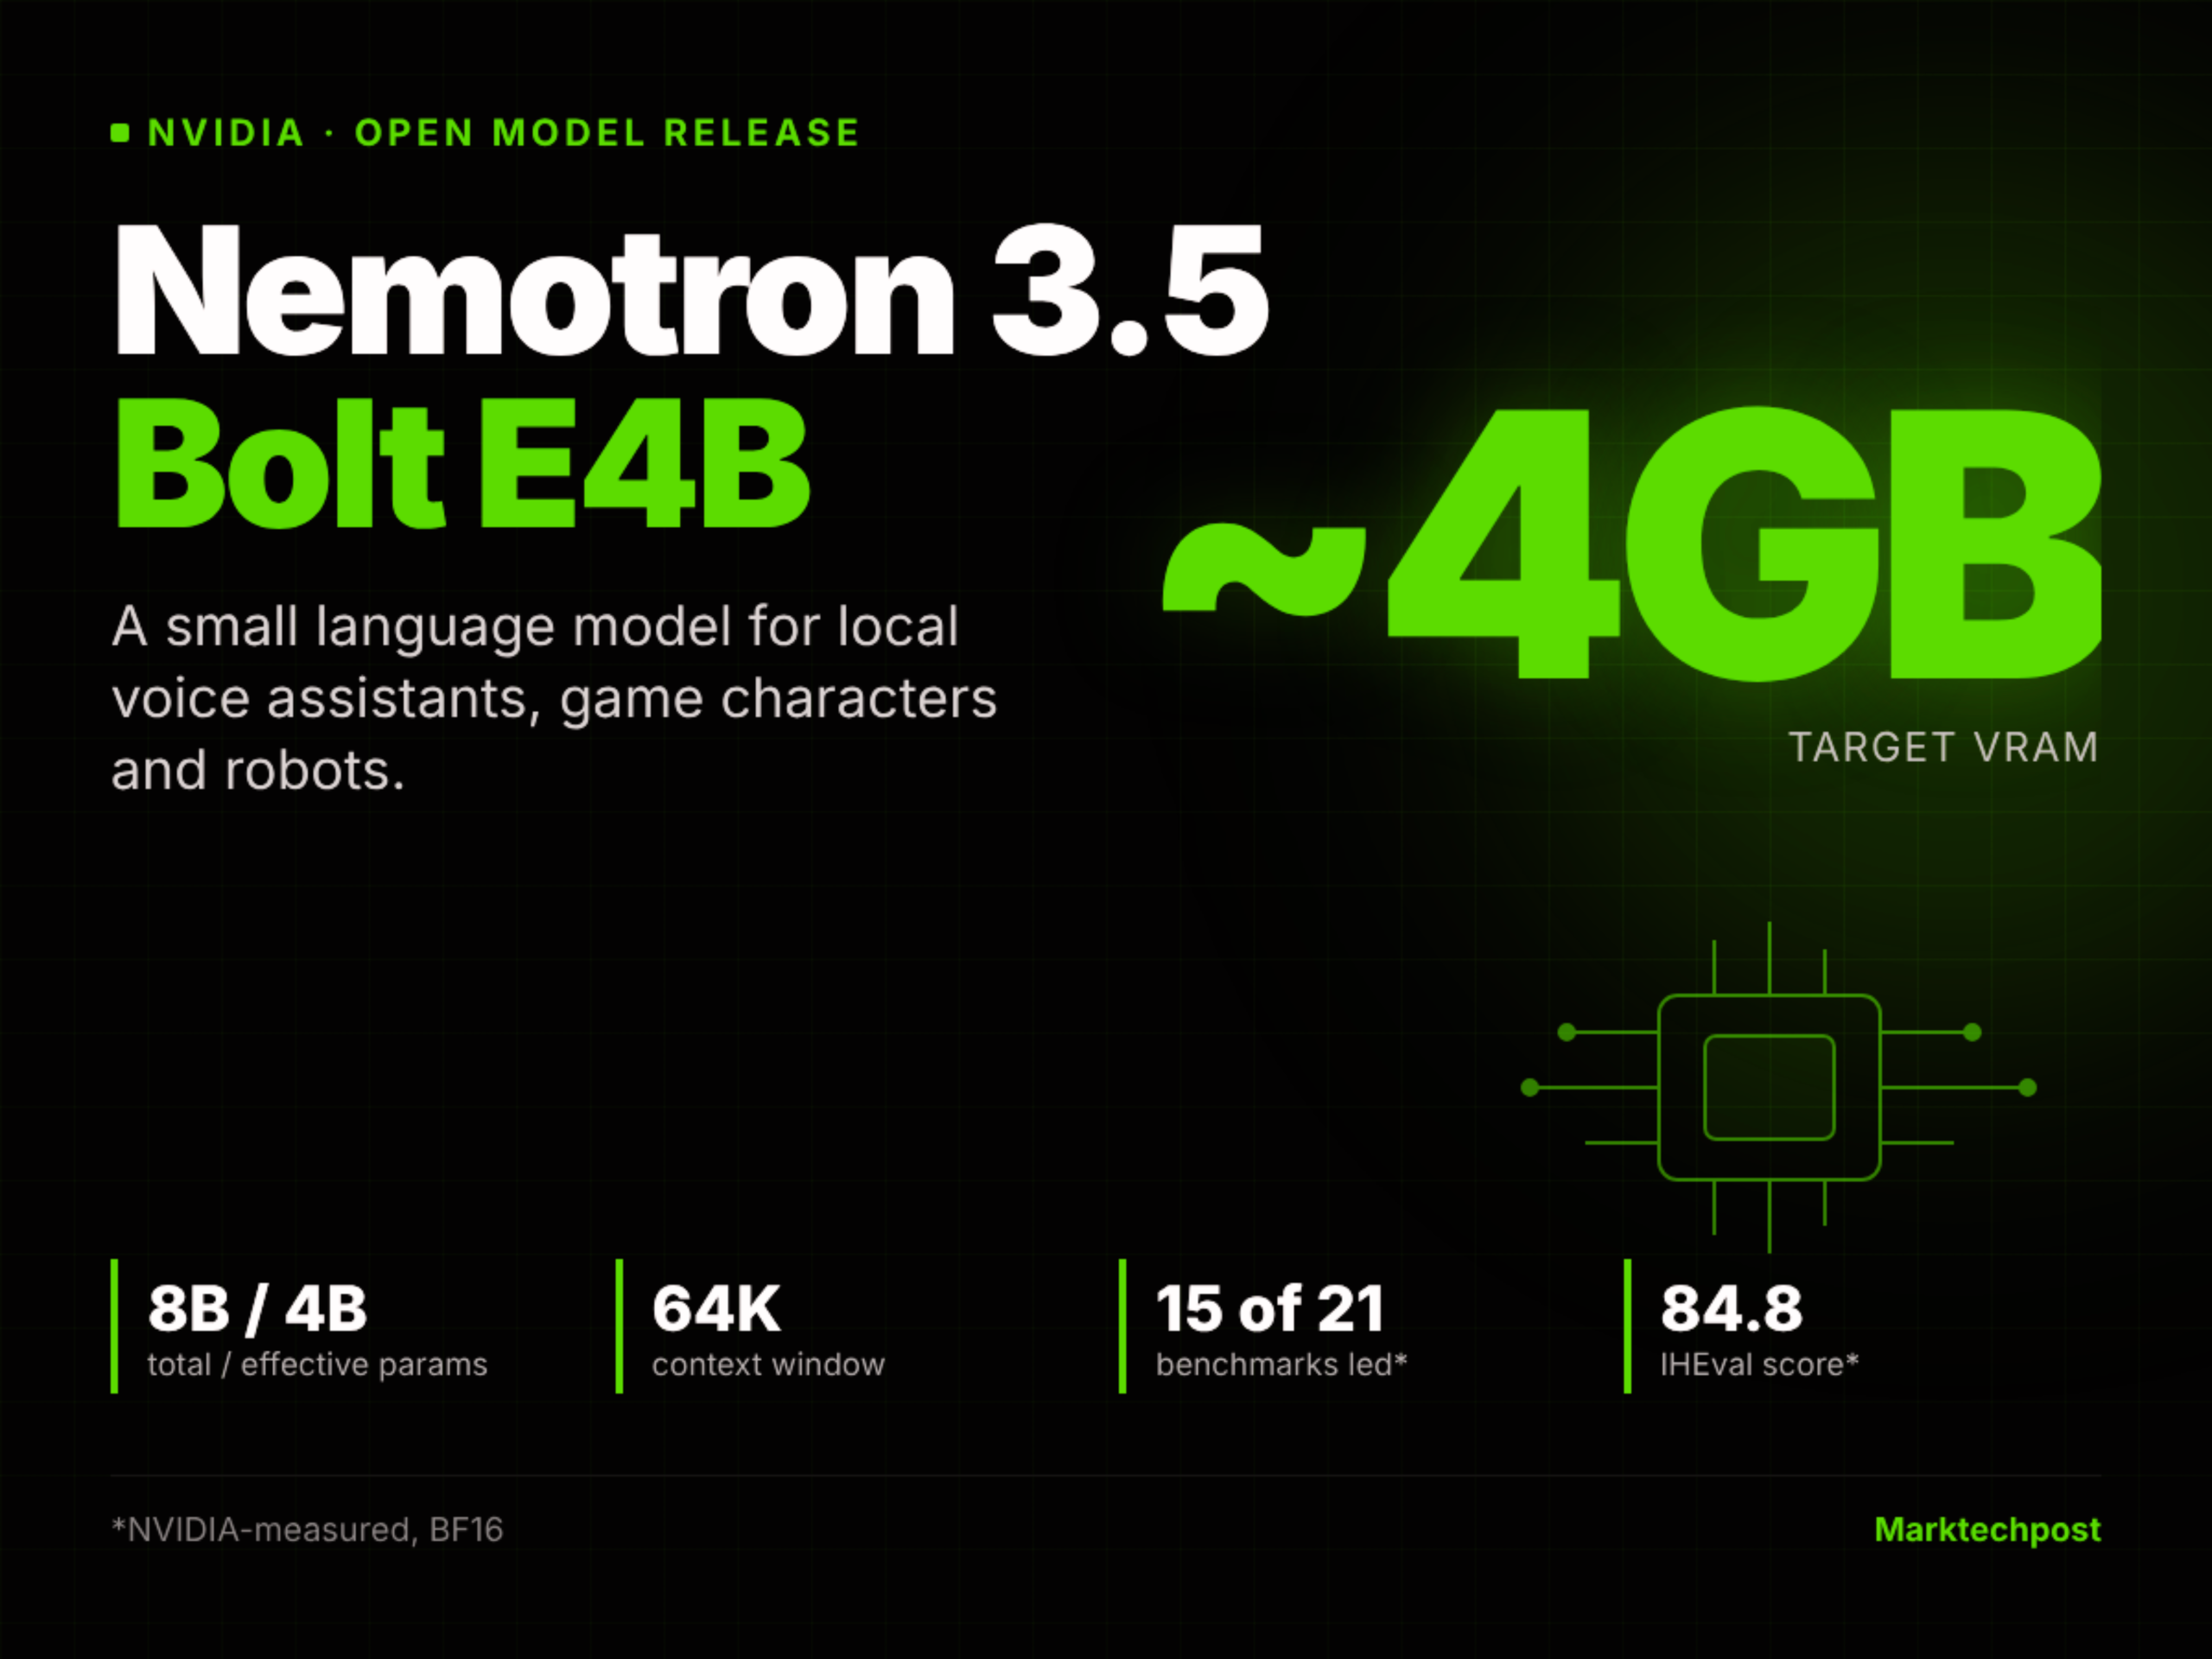
NVIDIA, leveraging Google’s Gemma 4 E4B model and employing only reinforcement learning (RL) for post-training, has launched Nemotron 3.5 Bolt E4B 4GB—a small open-source language model with 8B total parameters, 4B effective parameters, and a 64K context window. It is designed to run on edge devices such as RTX and Jetson with approximately 4GB of VRAM, supporting multi-turn tool calls and low-latency voice interaction.
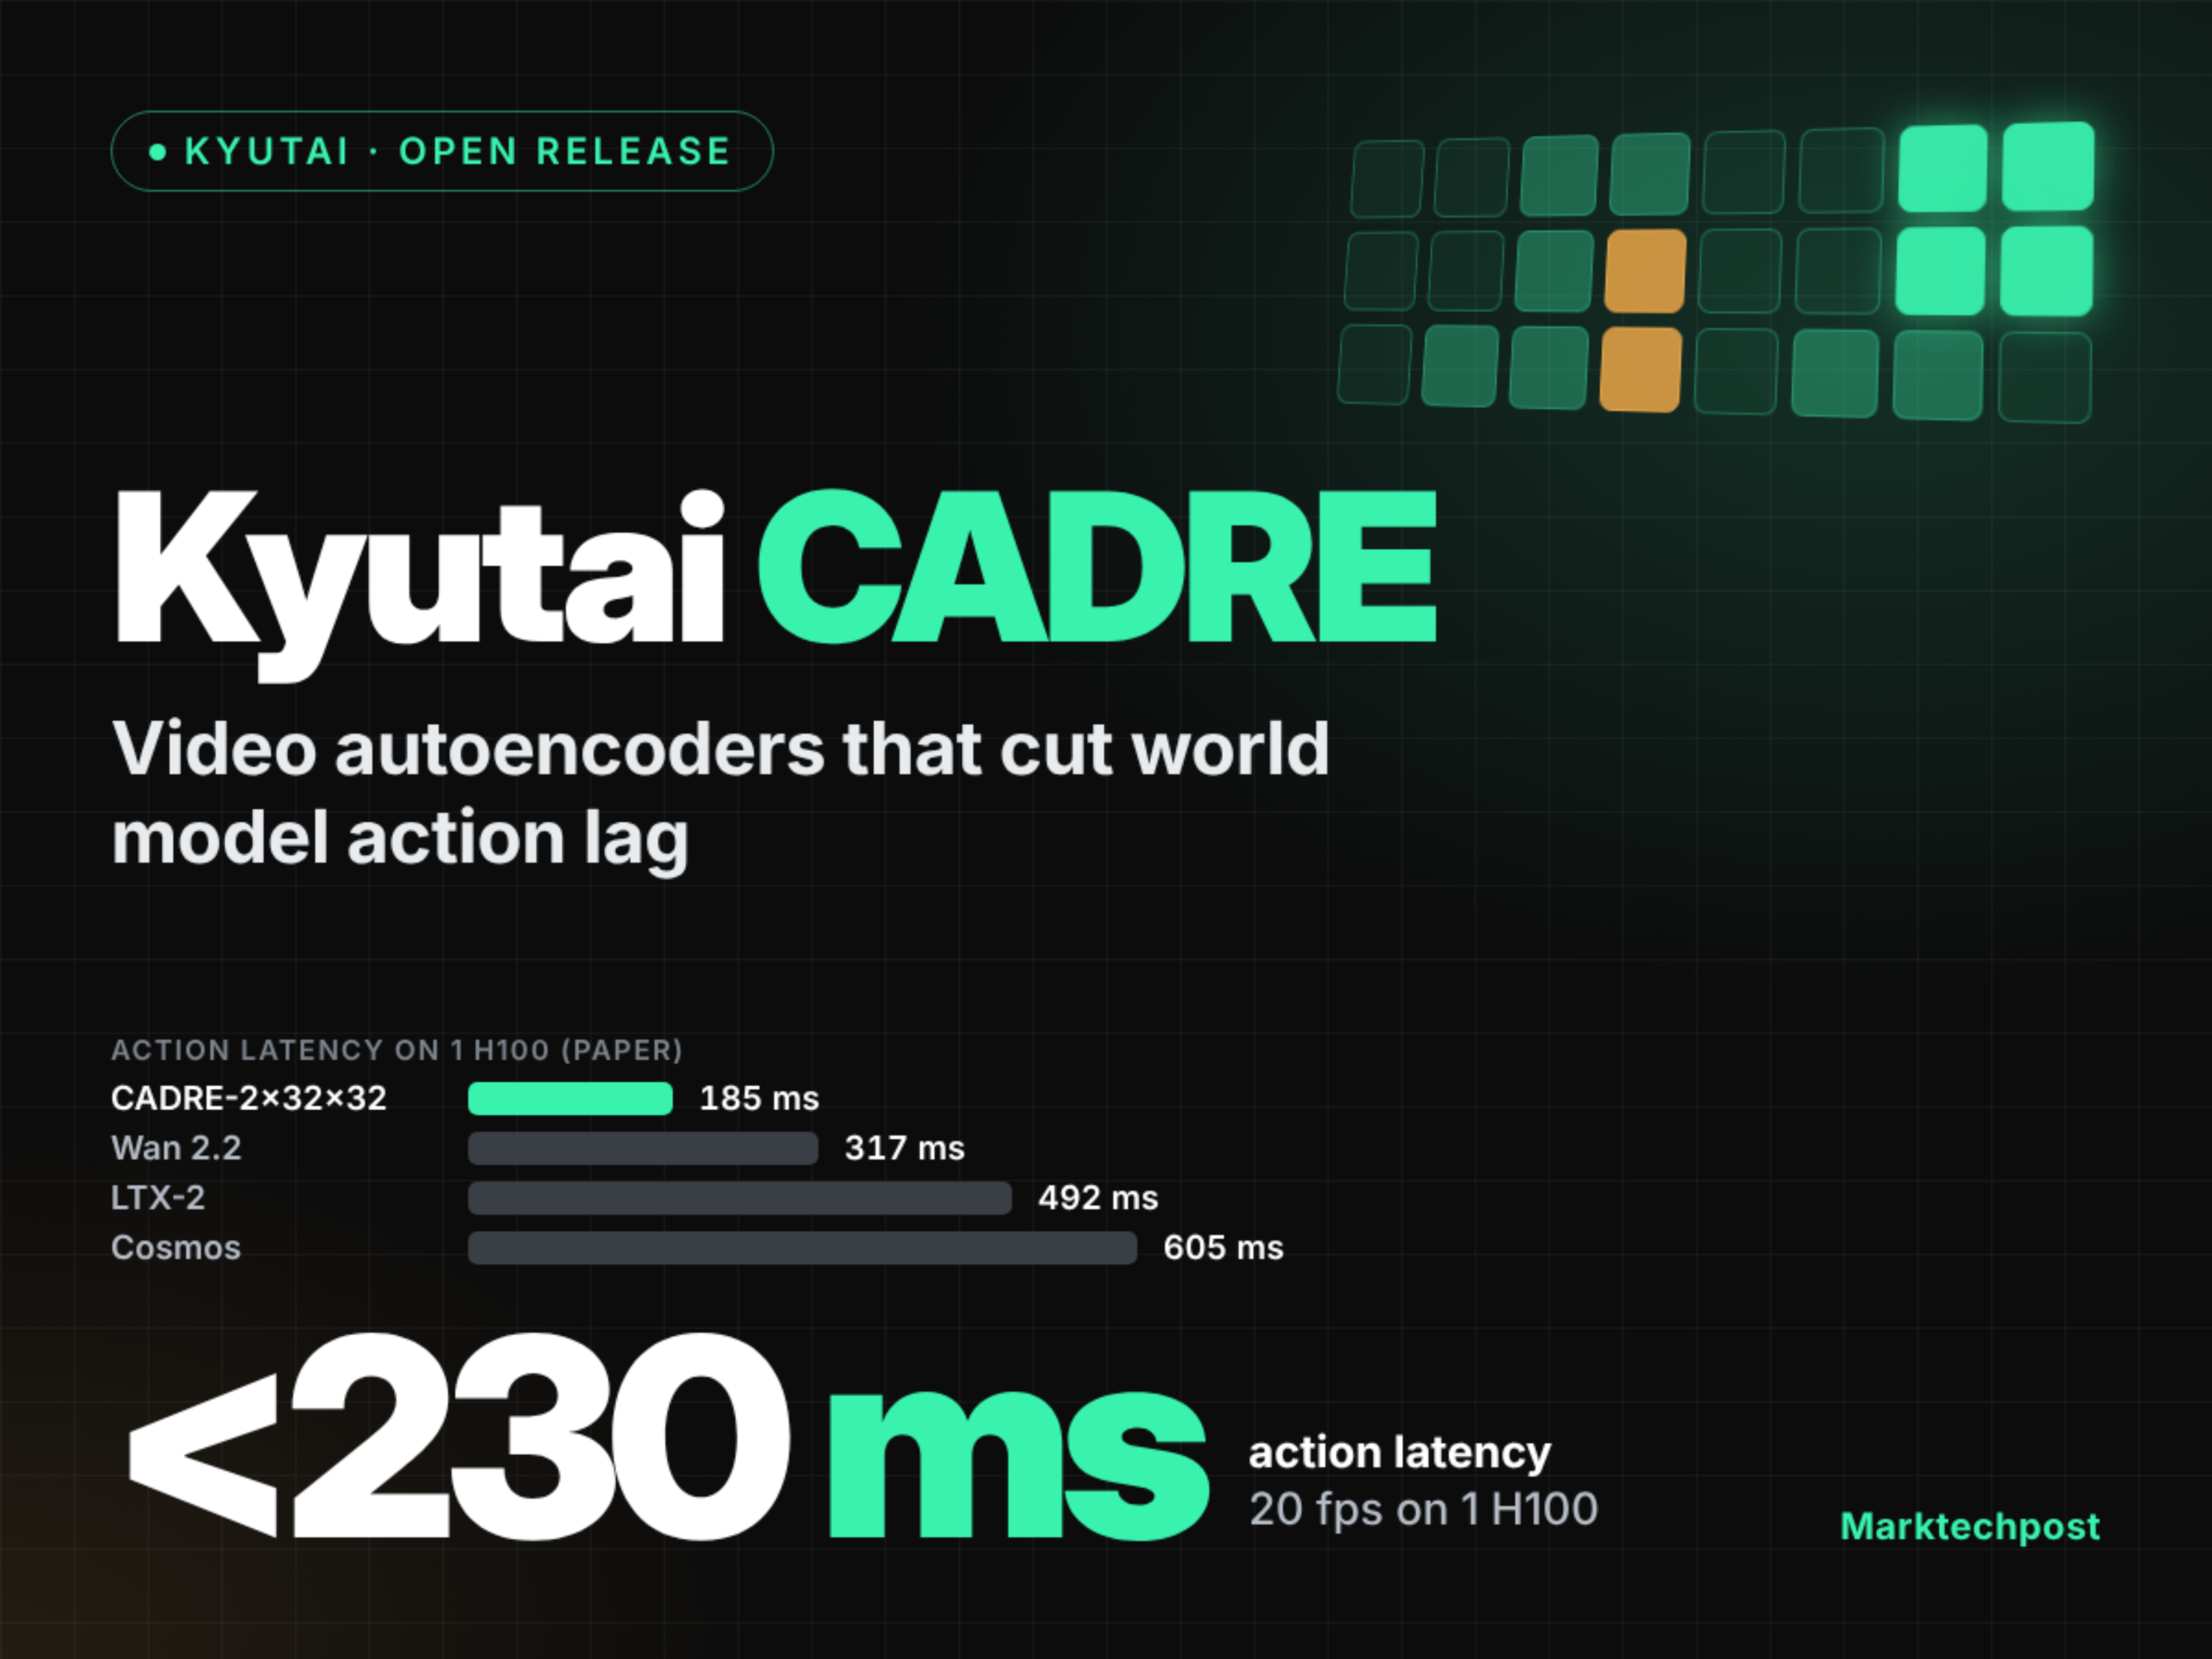
On October 23, 2026, Kyutai unveiled CADRE—a family of seven open-source causal diffusion-based video autoencoders designed to reduce action latency in world models. On a single H100 GPU, measured response latency was as low as 185 ms, with inference throughput reaching 23.4 fps, and the scene FVD metric dropping to 162.6 (compared to 599.7 for Wan 2.2). However, in robotic manipulation tasks, its action following rate (ARR) lagged behind both Wan 2.2 and Cosmos.
At the GTC Berlin conference, NVIDIA CEO Jensen Huang demonstrated Microduck, a robot developed by Pollen Robotics and now part of Hugging Face (which has been acquired by NVIDIA). This open-source robot can perform actions such as walking, sitting, pretending to sleep, and even doing backflips—all via voice commands. Following the video’s viral success, pre-orders exceeded 20,000 units the next day, positioning it as a potential holiday-season hit toy. These robots are trained using NVIDIA’s technology stack, enabling users to customize their training and share new skills.
Why it matters:The information is generated based on the provided TechCrunch article and fact list. The material states that Microduck is manufactured by Pollen Robotics, which was acquired by Hugging Face in 2025, and that NVIDIA acquired Hugging Face in September of the same year. The pre-sale data, feature descriptions, and delivery timelines mentioned in the text are directly quoted from the material, with no external information added.
Ride-hailing platform inDrive has signed memorandums of understanding with Pony.ai and NVIDIA, planning to launch Gen-7 autonomous taxi trials in Astana, the capital of Kazakhstan, in the first half of 2027. Initially, these vehicles will be equipped with safety drivers, with the ultimate goal of achieving fully driverless operation; NVIDIA will provide AI technology support, including the Hyperion platform and the Halos safety system.
At the GTC Berlin 2026 conference held at Berlin’s Tempodrom, NVIDIA CEO Jensen Huang unveiled several key advancements: the DSX POD modular AI factory, the Vera Rubin full-stack AI agent platform, the OpenShell security architecture, the Agent Knowledge Foundation knowledge layer, and the Agile ONE SN humanoid robot reference platform. He also announced a European AI investment commitment exceeding €10 billion, spanning more than 12,000 partners, while emphasizing that Europe is accelerating the development of an independent, controllable AI economic infrastructure.
NVIDIA, in collaboration with Hugging Face, has launched SimReady Central, a free and open-source simulation-ready (SimReady) 3D asset library built on OpenUSD. The initial release includes over 2,000 validated industrial-grade assets, covering robot bodies, end-effectors, AI factory infrastructure, and more, enabling developers to rapidly build physics-based AI training environments and digital twin scenarios.
Pollen Robotics and Hugging Face have jointly unveiled Microduck, a low-cost, open-source bipedal robot, integrating NVIDIA Isaac Lab 3.0 and the Newton physics engine. It supports training walking policies in GPU-accelerated parallel simulations, with domain randomization and high-fidelity actuator modeling—including backlash, latency, and friction—enhancing robustness during simulation-to-real transfer. The resulting ONNX model can be directly deployed on the physical robot.